

يمكن لنماذج Gemini Robotics ER التخطيط للمهام والاستدلال بشأن المساحة، واستنتاج الإجراءات التي يجب اتّخاذها والأشياء التي يجب نقلها لإكمال هدف معيّن. تعرض هذه الصفحة مثالاً على تنفيذ عملية اختيار ونقل من خلال واجهة برمجة تطبيقات مخصّصة للروبوتات لتنظيم مهمة وضع عنصر في وعاء.
للاطّلاع على رمز قابل للتنفيذ بالكامل، يُرجى مراجعة دليل Robotics.
استخدام واجهة برمجة تطبيقات مخصّصة للروبوتات
يوضّح هذا المثال عملية تنظيم المهام باستخدام واجهة برمجة تطبيقات مخصّصة للروبوتات. ويقدّم واجهة برمجة تطبيقات وهمية مصمّمة لعملية اختيار ونقل. المهمة هي التقاط مكعّب أزرق ووضعه في وعاء برتقالي:
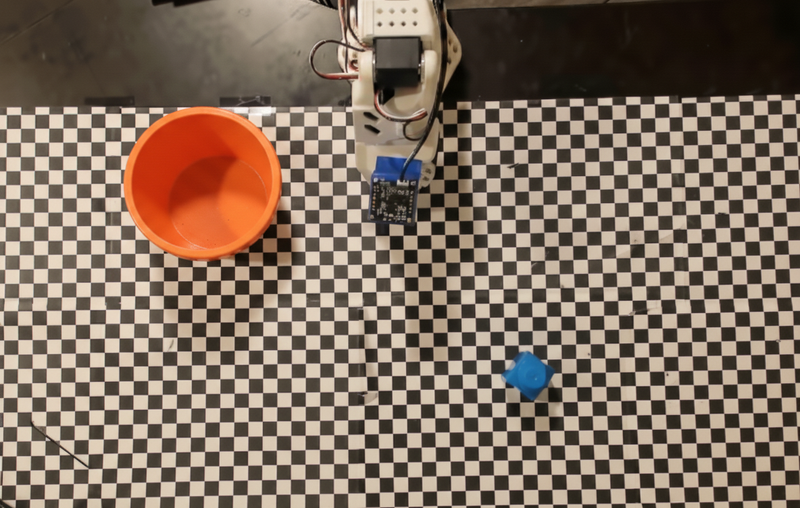
يستخدم هذا المثال واجهة برمجة التطبيقات الوهمية للروبوتات وتعريفات الأدوات التالية:
Python
from google import genai
from google.genai import types

client = genai.Client()

def move(x, y, high):
    print(f"Mock Robot: Moving to coordinates: {x}, {y}, {'high above table' if high else 'down at table level'}")

def setGripperState(opened):
    print(f"Mock Robot: {'Opening gripper' if opened else 'Closing gripper'}")

robot_origin_y = 300
robot_origin_x = 500

move_declaration = types.FunctionDeclaration(
    name="move",
    description="Moves the arm to the given coordinates.",
    parameters=types.Schema(
        type=types.Type.OBJECT,
        properties={
            "x": types.Schema(type=types.Type.INTEGER, description="X coordinate relative to the origin"),
            "y": types.Schema(type=types.Type.INTEGER, description="Y coordinate relative to the origin"),
            "high": types.Schema(type=types.Type.BOOLEAN, description="Set to True to lift the robot arm above the scene. Set to False to place the gripper on the surface."),
        },
        required=["x", "y", "high"],
    ),
)

set_gripper_state_declaration = types.FunctionDeclaration(
    name="setGripperState",
    description="Opens or closes the robot's gripper.",
    parameters=types.Schema(
        type=types.Type.OBJECT,
        properties={
            "opened": types.Schema(type=types.Type.BOOLEAN, description="True opens the gripper, False closes the gripper."),
        },
        required=["opened"],
    ),
)

robot_tools = types.Tool(function_declarations=[move_declaration, set_gripper_state_declaration])
يرسل المثال التالي الطلب والصورة إلى النموذج مع تعريفات الأدوات. ثم يتم تشغيل حلقة وكيل: بعد كل استجابة من النموذج، يتم تنفيذ أي استدعاءات مطلوبة للدوال (move وsetGripperState)، ويتم عرض النتائج مرة أخرى على النموذج، وتتكرر العملية إلى أن يتوقف النموذج عن استدعاء الدوال أو يتم بلوغ الحد الأقصى للخطوات.
Python
with open("robot-api-example.png", "rb") as f:
    img_bytes = f.read()

prompt = (
    "You are a robotic arm with six degrees-of-freedom. "
    f"The origin point for calculating the moves is at normalized point y={robot_origin_y}, x={robot_origin_x}. "
    "Use this as the new (0,0) for calculating moves, allowing x and y to be negative.\n\n"
    "Find the blue block and the orange bowl. Calculate their coordinates relative to the origin.\n"
    "Perform a pick and place operation where you pick up the blue block and place it into the orange bowl. "
    "Call the appropriate sequence of functions to complete this operation."
)

contents = [
    types.Content(role="user", parts=[
        types.Part.from_bytes(data=img_bytes, mime_type="image/png"),
        types.Part(text=prompt),
    ])
]

print("\n--- Executing Orchestrated Plan ---")

max_steps = 15  # Safety limit to prevent infinite loops
step_count = 0

# The Agentic Loop
while step_count < max_steps:
    step_count += 1

    response = client.models.generate_content(
        model="gemini-robotics-er-2-preview",
        contents=contents,
        config=types.GenerateContentConfig(
            tools=[robot_tools],
            thinking_config=types.ThinkingConfig(thinking_level="low"),
        ),
    )

    # Add model response to conversation history
    contents.append(response.candidates[0].content)

    # Check for function calls
    function_calls = [part for part in response.candidates[0].content.parts if part.function_call]

    if not function_calls:
        # Model is done calling functions
        print("Sequence complete.")
        print(f"Model Summary: {response.text}")
        break

    # Execute function calls and collect results
    function_response_parts = []
    for part in function_calls:
        fc = part.function_call
        if fc.name == "move":
            move(**fc.args)
        elif fc.name == "setGripperState":
            setGripperState(**fc.args)

        function_response_parts.append(
            types.Part.from_function_response(
                name=fc.name,
                response={"status": "success"},
            )
        )

    # Send function results back to model
    contents.append(types.Content(role="user", parts=function_response_parts))
يعرض ما يلي ناتجًا محتملاً للنموذج استنادًا إلى الطلب وواجهة برمجة التطبيقات الوهمية للروبوتات. يشمل الناتج نتائج استدعاءات دالة الروبوت التي رتّبها النموذج معًا.
--- Executing Orchestrated Plan ---
Mock Robot: Opening gripper
Mock Robot: Moving to coordinates: 160, 440, high above table
Mock Robot: Moving to coordinates: 160, 440, down at table level
Mock Robot: Closing gripper
Mock Robot: Moving to coordinates: 160, 440, high above table
Mock Robot: Moving to coordinates: -250, 60, high above table
Mock Robot: Moving to coordinates: -250, 60, down at table level
Mock Robot: Opening gripper
Mock Robot: Moving to coordinates: -250, 60, high above table
Sequence complete.
Model Summary: I have completed the task of picking up the blue block and placing it into the orange bowl.
الخطوات التالية
- الروبوتات مع البث: البث في الوقت الفعلي مع ميزة استدعاء الدوال (Gemini Robotics ER 2 فقط)
- فهم الفيديو: تتبُّع تقدّم المهام من الفيديو (ER 2 فقط)
- الاستدلال المكاني: أمثلة على الإشارة والتتبُّع ومربع الإحاطة